Workspace
Physical limits of the Dobot Magician, from sections 2.3 and 2.4 of the Dobot Magician V2 User Guide (DobotLab-based) V2.3.1.
Specifications
| Item | Value |
|---|---|
| Base (J1) | -90° to +90° |
| Rear arm (J2) | 0° to 85° |
| Forearm (J3) | -10° to +90° |
| End-effector rotation (J4) | -90° to +90° |
| Rear arm length | 135 mm |
| Forearm length | 147 mm |
| Maximum reach | 320 mm |
| Maximum payload | 500 g |
| Repeated positioning accuracy | 0.2 mm |
Coordinate system
The origin is the center of the base, rear-arm, and forearm motors. X points forward, Y to the left, and Z up. R is the rotation of the end-effector servo and exists only when an end effector with a servo, such as the suction cup or the gripper, is installed.
Reachable region
The base turns 90° to each side, so targets behind the base (x < 0) are out of reach. The range of reachable heights depends on the horizontal distance from the base axis.
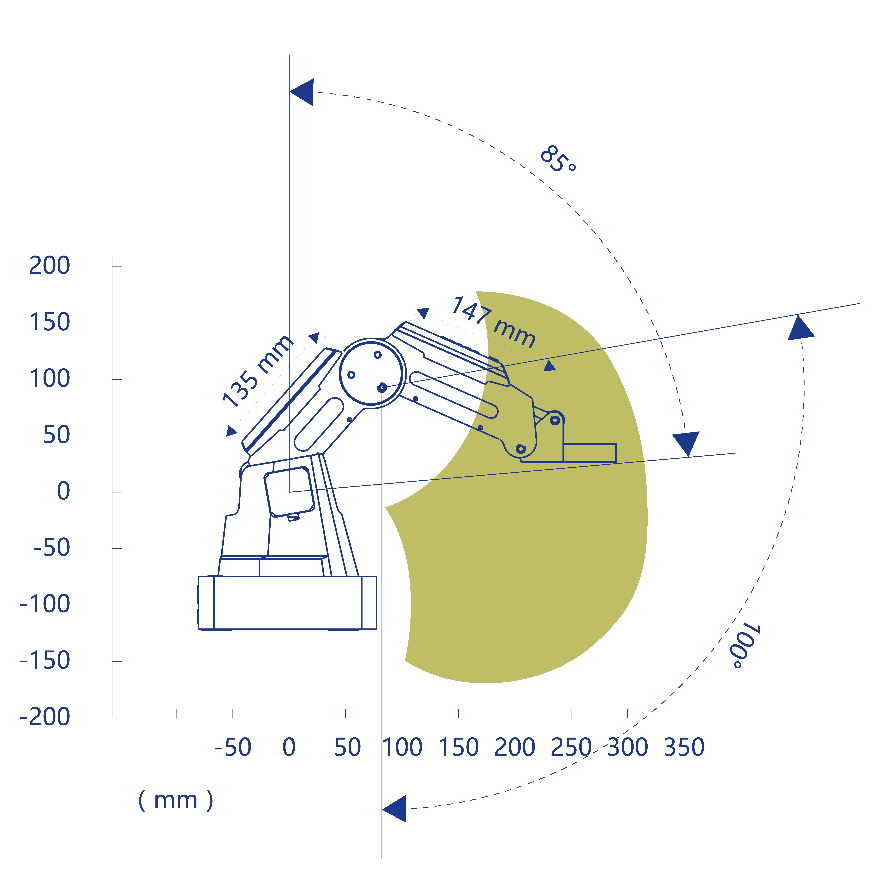
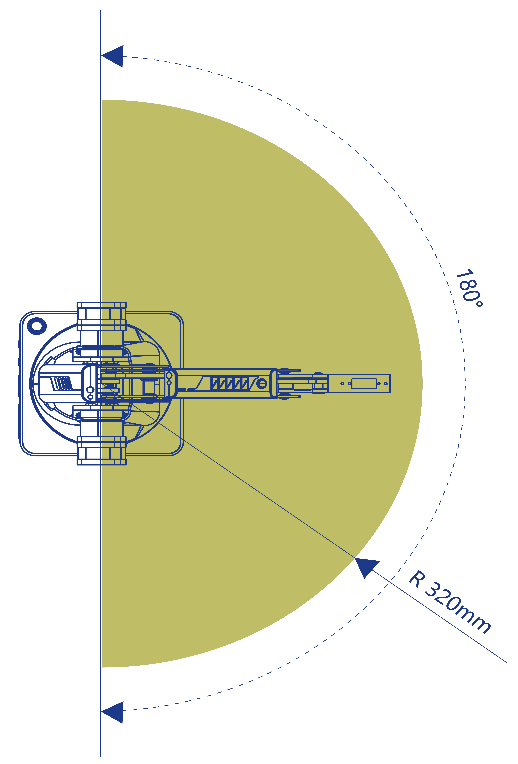
Side view (Figure 2.2) and top view (Figure 2.3) of the user guide. Dimensions in mm.
Reference bounds
The [workspace] section of the configuration file holds the bounds of the reachable region for reference, in mm: min_radius_mm and max_radius_mm (distance from the base axis), z_min_mm, and z_max_mm. The values come from the maximum reach and Figure 2.2. A target outside the bounds is out of reach; a target inside can still be out of reach, for example far out and high. Neither the arm nor pydobotlab checks moves against them. Programs can read them with get_config()["workspace"] from pydobotlab.config, as examples/draw_smiley.py does to check its path before drawing. The bounds can be narrowed in the file, not widened.
Targets out of reach
A target out of reach sets a planning alarm, PLAN_INVERSE_CALCULATION (out of the workspace) or PLAN_INVERSE_LIMIT (beyond a joint limit), and ptp raises DobotKinematicError. A joint at its limit sets a LIMIT_POS_J* or LIMIT_NEG_J* alarm; the rear arm and forearm stretched or folded to their limit set LIMIT_POS_PARALLELOGRAM or LIMIT_NEG_PARALLELOGRAM. See Alarm bitmask and Alarms and recovery.
The simulator applies the joint ranges and arm lengths to point-to-point targets. It does not limit jogging.